Rosalind Franklin: Optimizing Locomotion for the Oxia Planum Descent
ESA engineers refine the Rosalind Franklin rover's locomotion systems, preparing the six-wheeled explorer for the complex terrain of Mars' Oxia Planum.
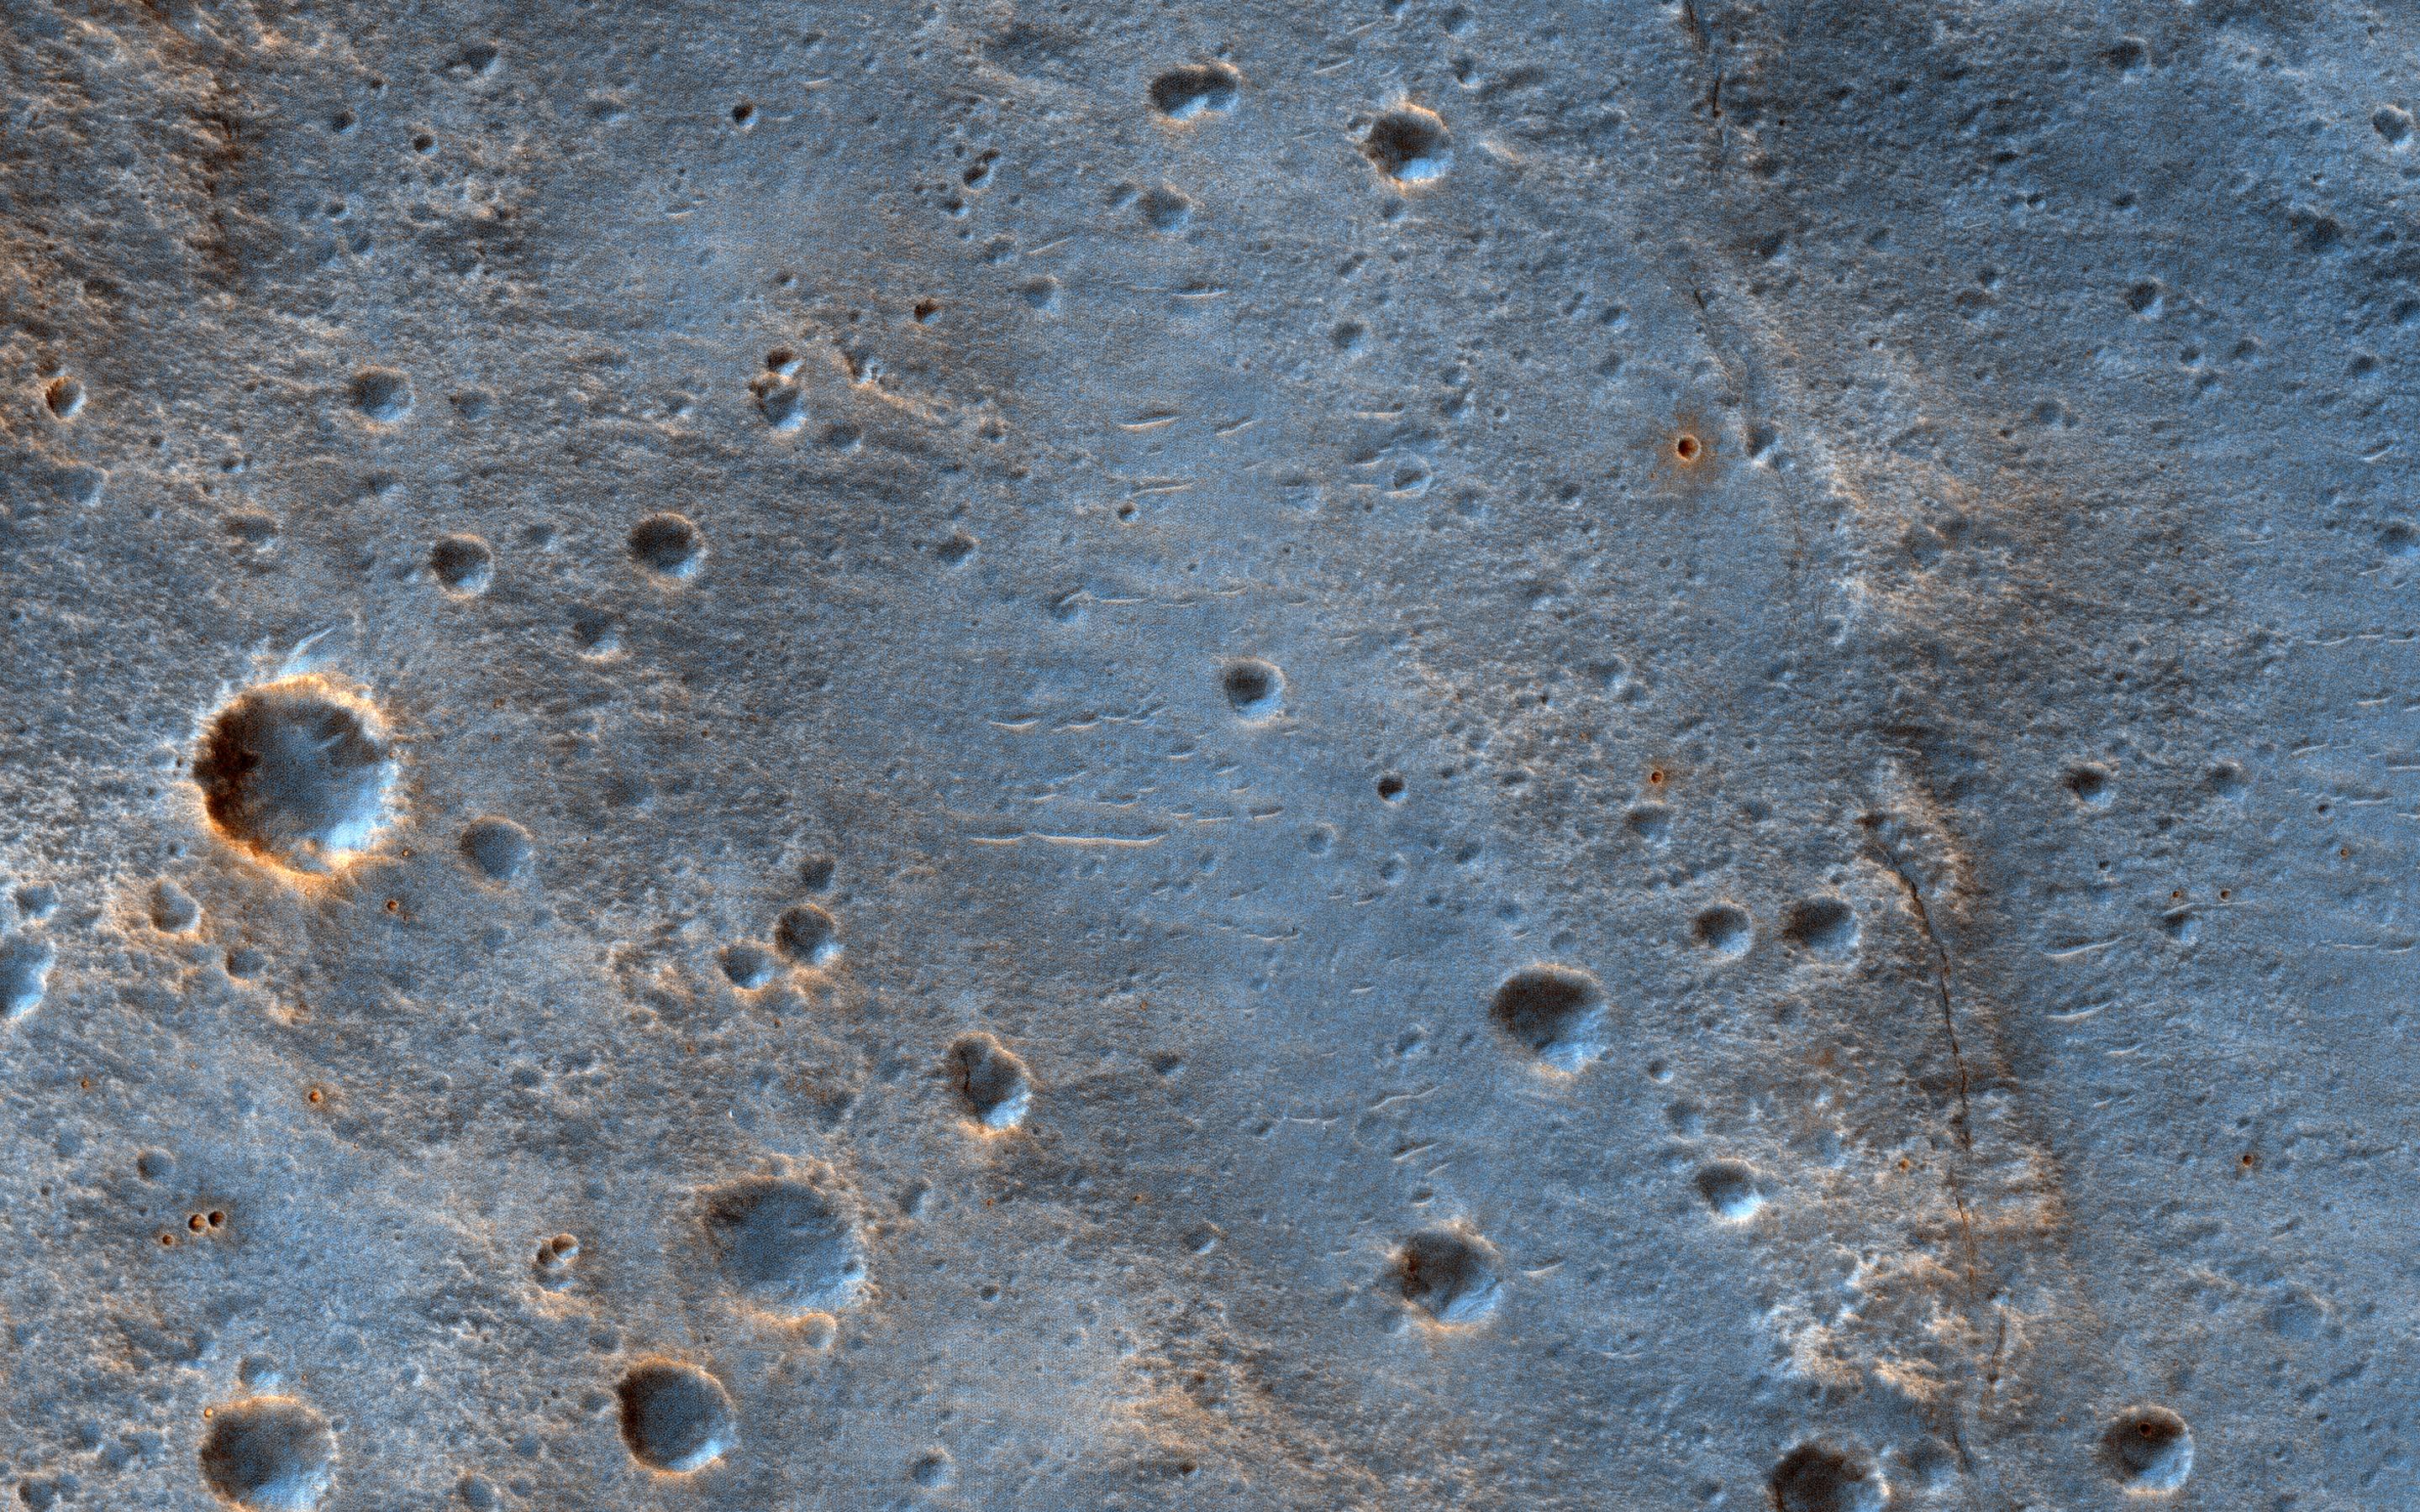
Technical Readiness: Locomotion and Descent
European Space Agency (ESA) engineers are finalizing the operational protocols for the Rosalind Franklin rover as it nears its deployment phase for the ExoMars mission. According to ESA YouTube, the focus has shifted to the critical transition from the landing platform to the Martian surface at Oxia Planum.
Terrain Adaptation
The rover utilizes a sophisticated six-wheel drive system, designed to navigate the uneven, rocky topography of the red planet. Each wheel is independently actuated, allowing for high-torque maneuvers and precise steering. Current testing involves simulating the egress—the high-stakes drive down the ramps of the landing module. A single misalignment during this phase could jeopardize the entire mission profile.
Drilling for Biosignatures
Once grounded, the Rosalind Franklin’s primary objective is to seek signs of past life. Unlike previous missions, this rover is equipped with a high-capacity drill capable of reaching depths of two meters. Subsurface sampling is essential to avoid the harsh radiation environment of the surface, which degrades organic molecules over time. ESA teams are currently validating the software sequences that will govern these autonomous movements, ensuring the rover can detect and bypass obstacles while maintaining its trajectory toward scientifically significant clay-rich regions.
Success depends on the integration of the locomotion control system and the onboard panoramic cameras. This synergy allows the rover to map its immediate environment and execute commands with minimal ground-station latency. The mission remains a cornerstone of European planetary exploration, pushing the boundaries of autonomous robotics in deep space.